Basheer Al-Tawil
PhD researcher in Robotics and AI at Otto von Guericke University
Robots that map, understand and move among people.
I build the perception and navigation software that lets a mobile robot keep an accurate map while people walk through it, recognise what they are doing, and plan a path that respects their space.
From sensor data to polite motion
My work follows the data through a mobile robot, in five steps.
Results so far
How these were achieved- Error
Lower trajectory error than ORB-SLAM3 in scenes with moving people, from 0.404 m to 0.015 m on TUM RGB-D.
SAR-SLAM, Robotics 2026 - Accuracy
Higher Action Recognition accuracy on UCF-101 with a ResNet-18, Bi-LSTM and attention model that runs on a mobile robot.
Sensors 2025 - Goals
High percentage of navigation goals reached after fusing four RGB-D cameras with two LiDARs for 2D mapping.
Sensors 2025 - Citations
More than 140 citations for my review of visual SLAM methods for robotics, my most-cited paper.
Frontiers in Robotics and AI 2024
Selected publications
All 13 publications-
2026
SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
Basheer Al-Tawil, Magnus Jung, Thorsten Hempel, Ayoub Al-Hamadi. Robotics 15(7), 136, 2026
-
2025
Mobile Robot Navigation with Enhanced 2D Mapping and Multi-Sensor Fusion
Basheer Al-Tawil, Adem Candemir, Magnus Jung, Ayoub Al-Hamadi. Sensors 25(8), 2408, 2025
-
2025
Multi-Head Attention-Based Framework with Residual Network for Human Action Recognition
Basheer Al-Tawil, Magnus Jung, Thorsten Hempel, Ayoub Al-Hamadi. Sensors 25(9), 2930, 2025
-
2024
A Review of Visual SLAM for Robotics: Evolution, Properties, and Future Applications
Basheer Al-Tawil, Thorsten Hempel, Ahmed Abdelrahman, Ayoub Al-Hamadi. Frontiers in Robotics and AI 11, 1347985, 2024
Open-source projects
All 8 projectsRoboCraft: a reconfigurable three-arm SCARA cell
Three SCARA robots that work alone or lock onto a hexagonal platform and become one parallel robot.
- ROS 2 Humble
- Gazebo Fortress
- ros2_control
- C++17
AgroBot: a robot arm for greenhouse work
A 4-axis arm on a rail trolley that harvests strawberries, transplants seedlings, inspects plants and pulls weeds.
- ROS 2 Humble
- Gazebo Fortress
- ros2_control
- C++17
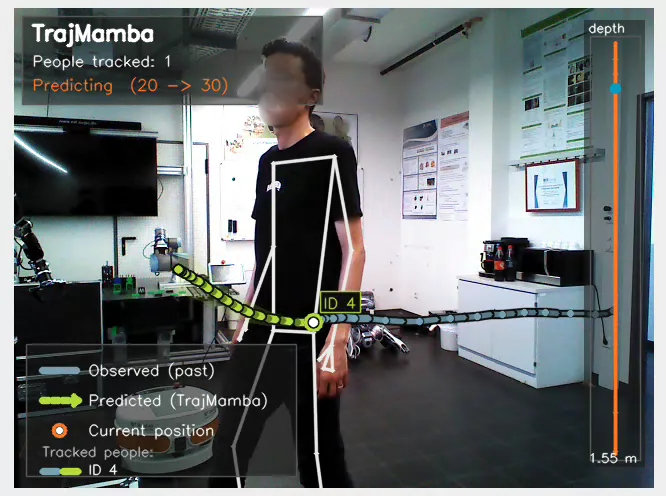
TrajMamba: predicting where people will walk
A 262 K-parameter Mamba model that predicts the next three seconds of a person’s path from an RGB-D camera, in real time on a Jetson Orin.
- ROS 2 Humble and Jazzy
- PyTorch
- Mamba
- MediaPipe Pose
Tutorials and notes
All 18 posts-
Host a website for free with GitHub and Cloudflare, step by step
How to take a website from a folder of files to a live address with your own domain, HTTPS, free email forwarding and visitor statistics. Design, repository, Cloudflare deployment, domain, launch checklist and measuring, with the mistakes to avoid.
Tutorials15 min read -
Sending a designed HTML email from Gmail, explained simply
Why a beautiful email can arrive empty, what Gmail keeps and removes, two reliable ways to paste a designed email into Gmail, the three traps to avoid, and a short Python checker for your HTML.
Tutorials9 min read -
Dynamic Covariance Scaling, explained simply
How a SLAM system survives one wrong 'I've been here before': pose graphs, loop closures, why a single false loop closure can wreck a map, and how Dynamic Covariance Scaling (DCS) turns its volume down. A robot with a RealSense camera drives down a corridor to a lab and back, with every number from a runnable simulation.
SLAM15 min read
Work with me
I am open to research collaborations, industry R&D roles, postdoc positions and invited talks on mobile robotics, SLAM, perception and human-robot interaction.