Publications
Papers on SLAM, perception, understanding people and robot arms. Each entry links to the paper, and to the code where it is public.
11published works 201citations Counts from Google Scholar, October 2026.
2026
-
SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications
Robotics 15(7), 136, 2026
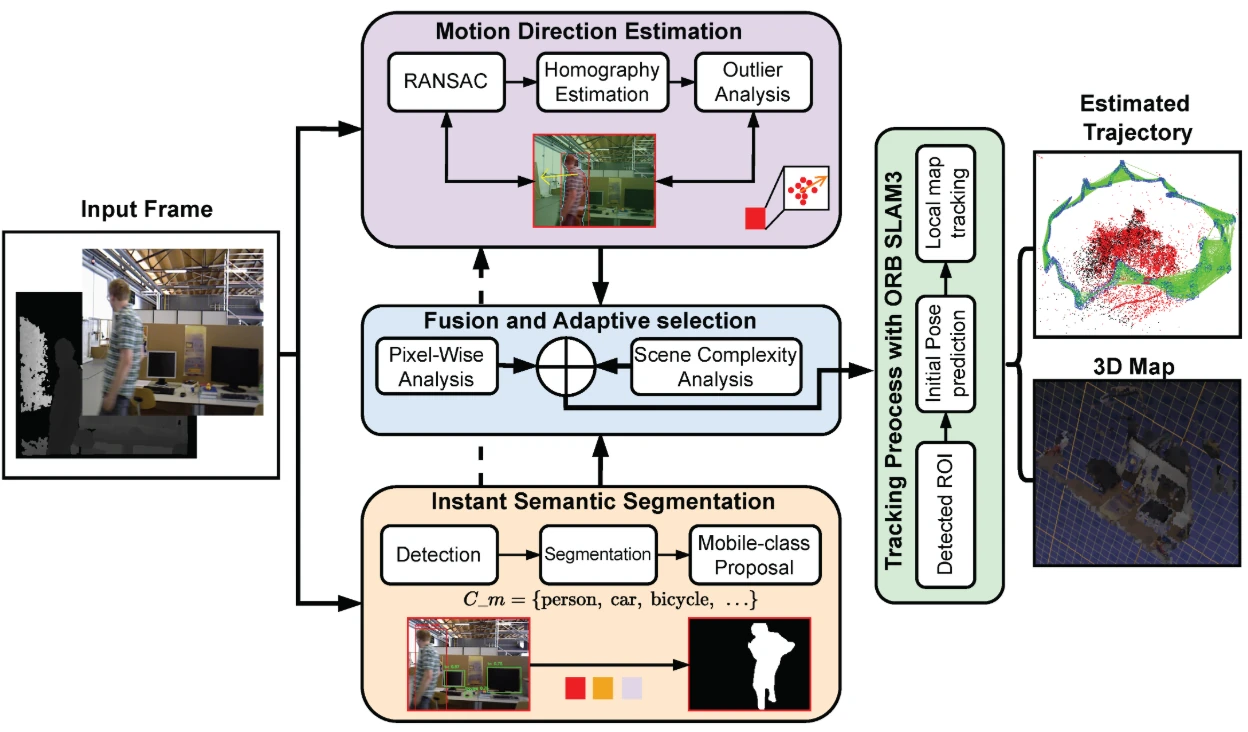
An RGB-D SLAM framework for scenes with moving people. YOLOv8 segmentation proposes dynamic objects, a RANSAC homography verifies which ones really move, and an adaptive fusion step filters their features before ORB-SLAM3. Absolute trajectory error drops by up to 96 % on dynamic TUM RGB-D sequences.
@article{altawil2026sarslam,
  title = {SAR-SLAM: Semantic-Aware Recognition for Dynamic SLAM in Robotic Applications},
  author = {Al-Tawil, Basheer and Jung, Magnus and Hempel, Thorsten and Al-Hamadi, Ayoub},
  journal = {Robotics},
  volume = {15},
  number = {7},
  year = {2026},
  publisher = {MDPI},
  pages = {136},
  doi = {10.3390/robotics15070136}
}
-
Deep Learning-Based Gaze Estimation: A Review
Robotics 15(4), 69, 2026
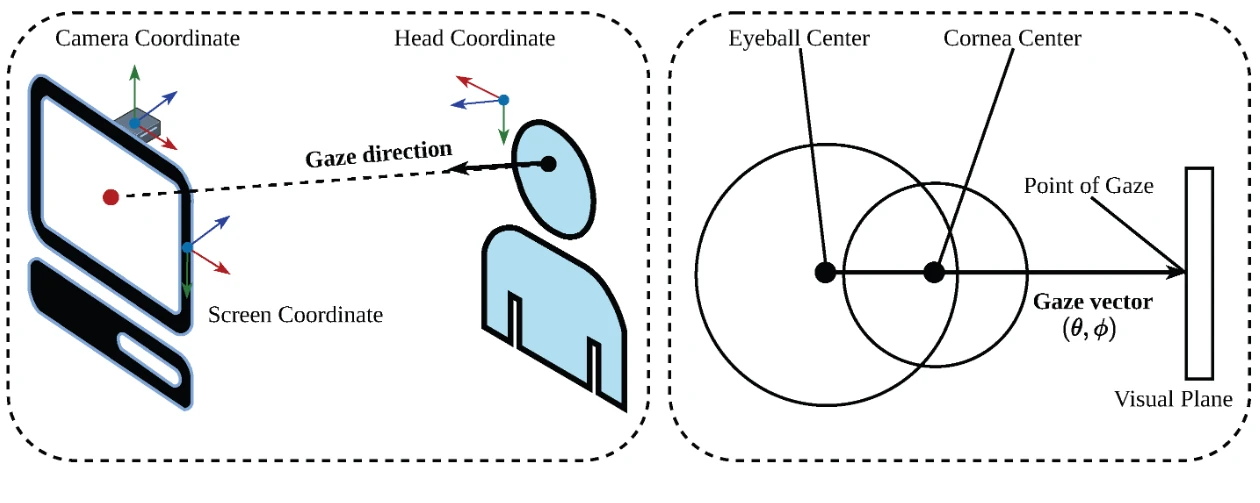
A review of deep-learning gaze estimation, from conventional methods to appearance-based networks, comparing input features, architectures and preprocessing and naming the open gaps.
@article{abdelrahman2026deep,
  title = {Deep Learning-Based Gaze Estimation: A Review},
  author = {Abdelrahman, Ahmed A. and Al-Tawil, Basheer and Al-Hamadi, Ayoub},
  journal = {Robotics},
  volume = {15},
  number = {4},
  year = {2026},
  publisher = {MDPI},
  pages = {69},
  doi = {10.3390/robotics15040069}
}
-
Real-Time Human Trajectory Prediction from RGB-D for Mobile Robots Using Bi-Mamba
ICCMA 2026
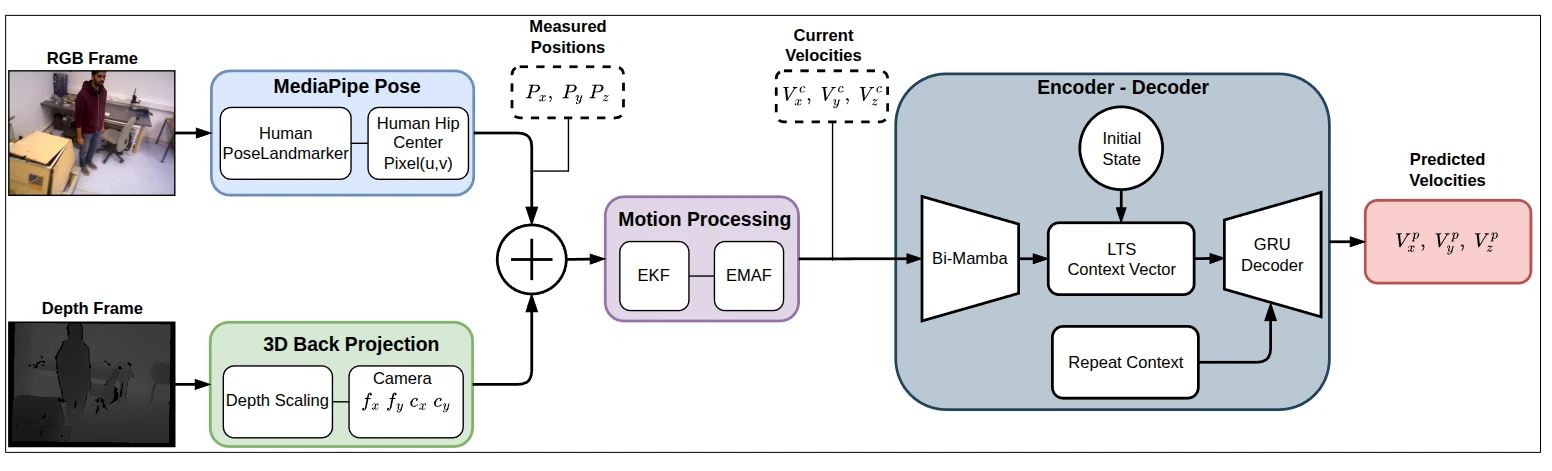
TrajMamba, a bidirectional Mamba model with a GRU decoder and about 262 K parameters, predicts the next three seconds of a person’s 3D path from RGB-D and runs in real time on a Jetson Orin.
@article{al2026real,
  title = {Real-Time Human Trajectory Prediction from RGB-D for Mobile Robots Using Bi-Mamba},
  author = {Al-Tawil, Basheer and Jung, Magnus and Al-Hamadi, Ayoub},
  journal = {ICCMA 2026},
  year = {2026},
  url = {https://arxiv.org/abs/2610.33916},
  note = {Accepted for publication}
}
-
REMA-Net: Real-Time Human Action Recognition via Caption-Guided Dual-Stream Attention
SSRN preprint
A lightweight dual-stream network that pairs an RGB stream with a BLIP caption stream through cross-modal knowledge distillation. 96.8 % on UCF-101, 73 % on HMDB-51 and 34.8 % on HAA-500, with 11.82 ms latency on a Jetson Nano.
Preprint, under reviewRead the preprint@article{altawil2026remanet, title = {REMA-Net: Real-Time Human Action Recognition via Caption-Guided Dual-Stream Attention}, author = {Al-Tawil, Basheer and Jung, Magnus and Al-Hamadi, Ayoub}, journal = {SSRN preprint}, year = {2026}, url = {https://papers.ssrn.com/sol3/papers.cfm?abstract_id=7357566} }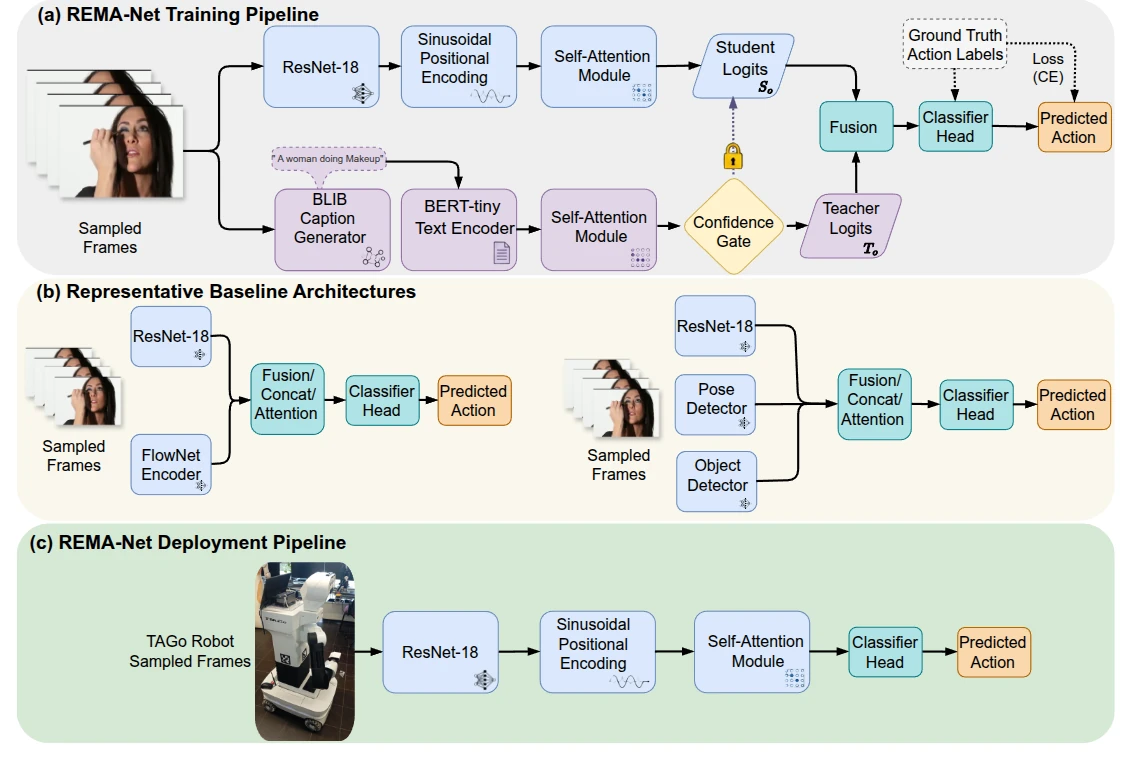
2025
-
Toward Truly Intelligent Autonomous Systems: A Taxonomy of LLM Integration for Everyday Automation
Robotics, Computer Vision and Intelligent Systems (ROBOVIS 2025), pp. 74–91, 2025
Three levels of wiring a large language model into a robot: open-loop, closed-loop and fully LLM-driven. Tested on the TIAGo robot and in simulation with GPT-4 and Vicuna.
@inproceedings{jung2025toward, title = {Toward Truly Intelligent Autonomous Systems: A Taxonomy of LLM Integration for Everyday Automation}, author = {Jung, Magnus and Hempel, Thorsten and Al-Tawil, Basheer and Yang, Qiaoyue and Wachsmuth, Sven and Al-Hamadi, Ayoub}, booktitle = {Robotics, Computer Vision and Intelligent Systems (ROBOVIS 2025)}, pages = {74--91}, year = {2025}, publisher = {Springer}, doi = {10.1007/978-3-032-00986-9_6} } -
Eye Contact Based Engagement Prediction for Efficient Human–Robot Interaction
Complex & Intelligent Systems 11, 286, 2025
Predicts whether a person is engaged with a robot from just two features, eye contact and distance, instead of more than a hundred. Real-time, with 80.73 % accuracy on the UE-HRI benchmark.
@article{jung2025eye, title = {Eye Contact Based Engagement Prediction for Efficient Human–Robot Interaction}, author = {Jung, Magnus and Abdelrahman, Ahmed and Hempel, Thorsten and Al-Tawil, Basheer and Yang, Qiaoyue and Wachsmuth, Sven and Al-Hamadi, Ayoub}, journal = {Complex & Intelligent Systems}, volume = {11}, year = {2025}, publisher = {Springer}, pages = {286}, doi = {10.1007/s40747-025-01902-z} } -
Multi-Head Attention-Based Framework with Residual Network for Human Action Recognition
Sensors 25(9), 2930, 2025
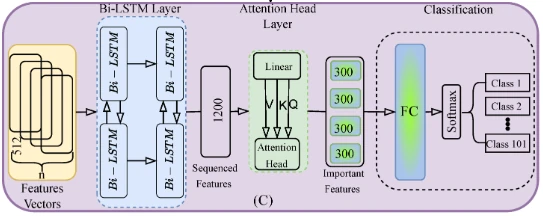
ResNet-18 features, a Bi-LSTM and multi-head attention, with optical-flow frame selection, reach 96.60 % accuracy on UCF-101. Validated on a mobile robot for real-time use.
@article{altawil2025multihead,
  title = {Multi-Head Attention-Based Framework with Residual Network for Human Action Recognition},
  author = {Al-Tawil, Basheer and Jung, Magnus and Hempel, Thorsten and Al-Hamadi, Ayoub},
  journal = {Sensors},
  volume = {25},
  number = {9},
  year = {2025},
  publisher = {MDPI},
  pages = {2930},
  doi = {10.3390/s25092930}
}
-
Mobile Robot Navigation with Enhanced 2D Mapping and Multi-Sensor Fusion
Sensors 25(8), 2408, 2025
RGB-D point clouds are projected to 2D, denoised and fused with LiDAR scans. Enhanced Gmapping (EGM) adds adaptive resampling and degeneracy handling, which makes mapping and navigation more robust indoors.
DOI: 10.3390/s25082408SJR Q1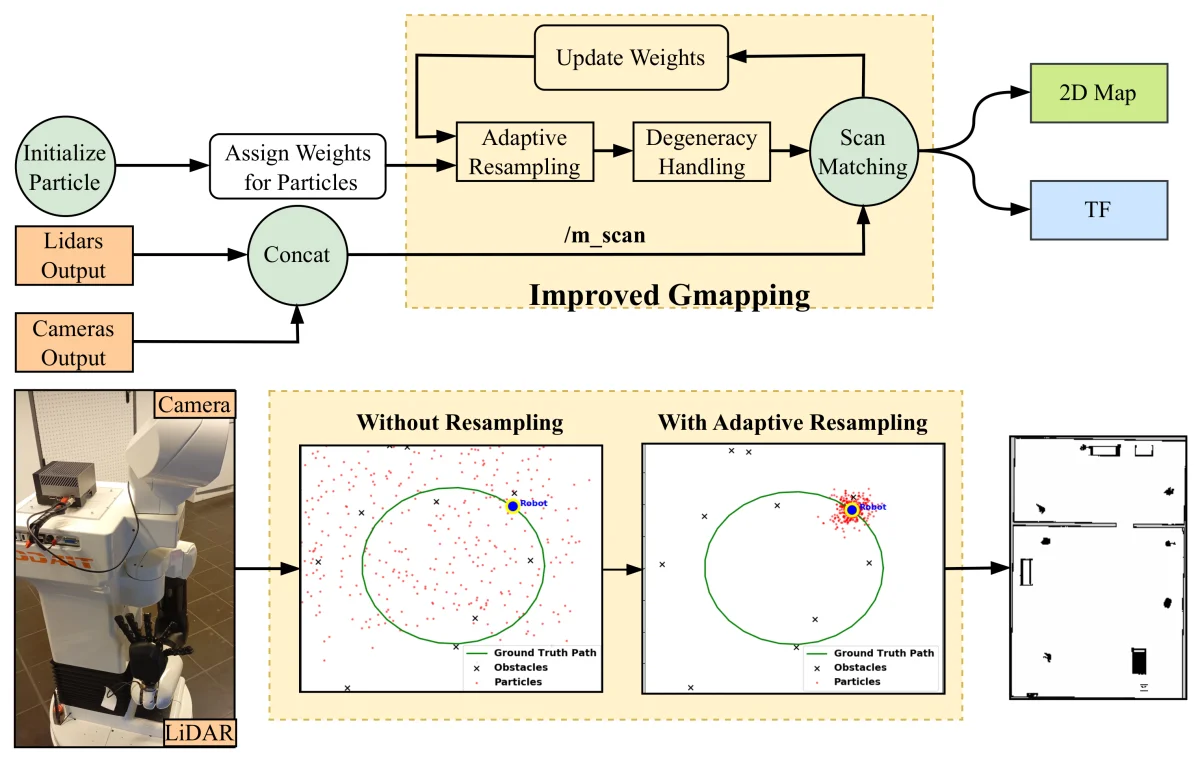
2024
-
A Review of Visual SLAM for Robotics: Evolution, Properties, and Future Applications
Frontiers in Robotics and AI 11, 1347985, 2024
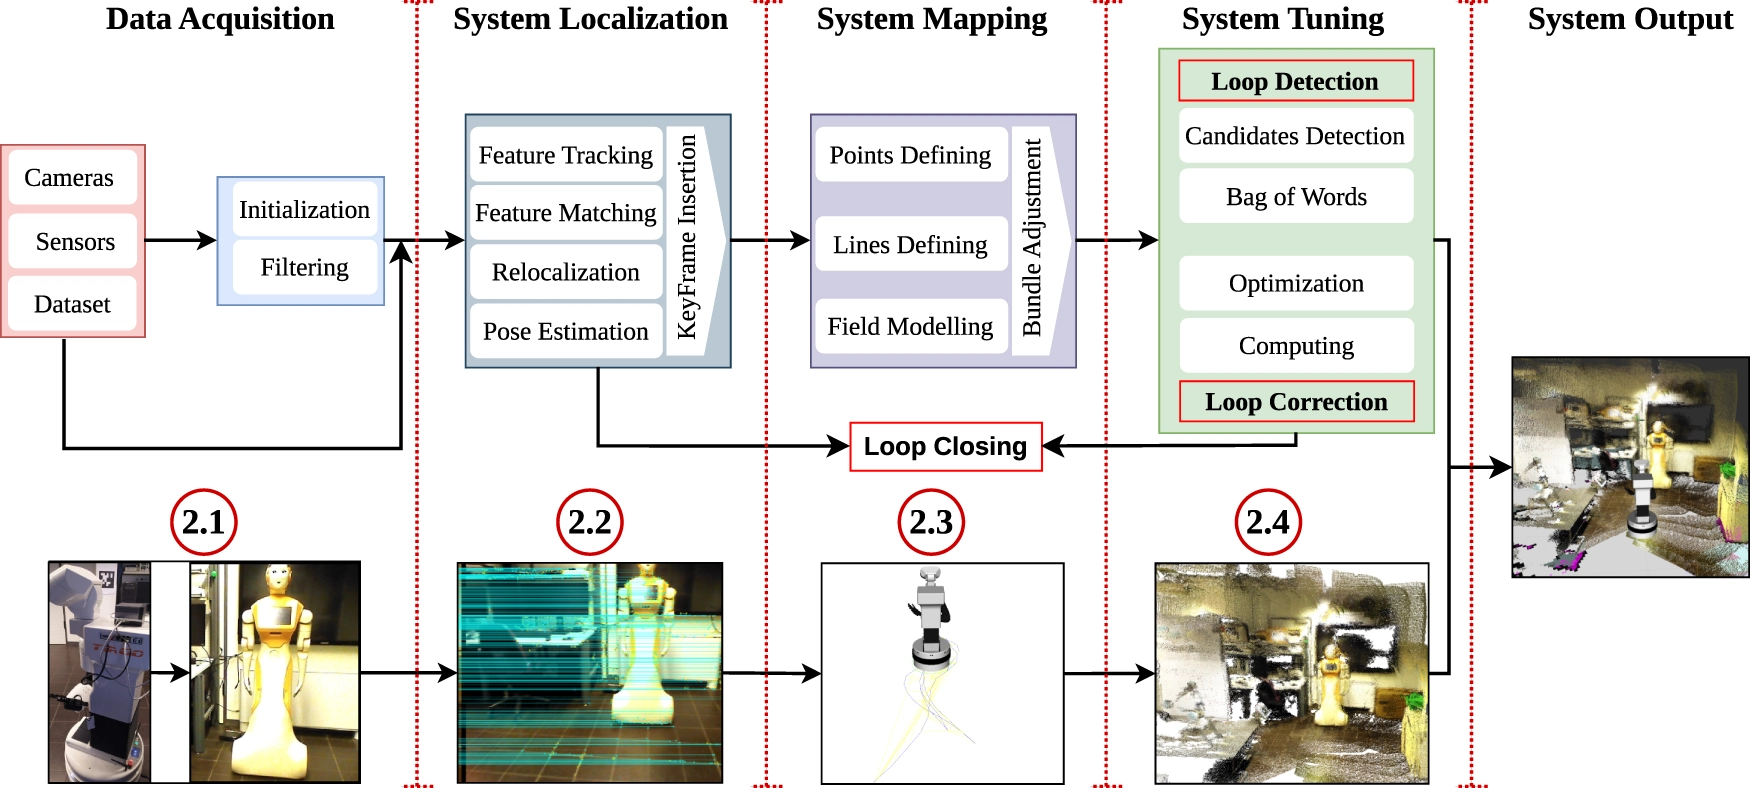
Traces how visual SLAM evolved, gives criteria for choosing a method for a given robot, and compares the major systems by their ROS support and benchmark results.
@article{altawil2024a,
  title = {A Review of Visual SLAM for Robotics: Evolution, Properties, and Future Applications},
  author = {Al-Tawil, Basheer and Hempel, Thorsten and Abdelrahman, Ahmed and Al-Hamadi, Ayoub},
  journal = {Frontiers in Robotics and AI},
  volume = {11},
  year = {2024},
  publisher = {Frontiers},
  pages = {1347985},
  doi = {10.3389/frobt.2024.1347985}
}
2023
-
Design and Analysis of a Four DoF Robotic Arm with Two Grippers Used in Agricultural Operations
International Journal of Applied Mathematics Electronics and Computers 11(2), pp. 79–87, 2023
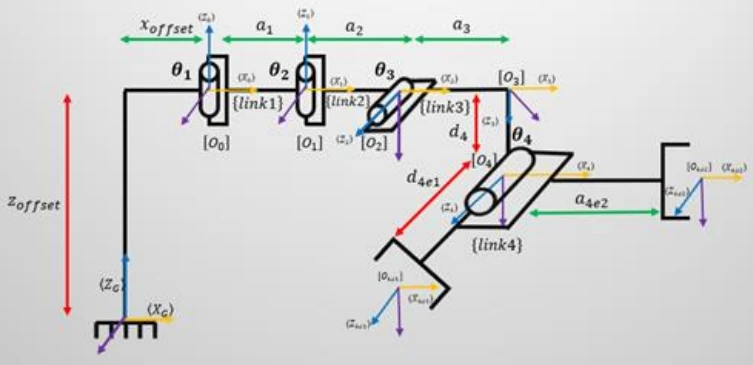
A 4-DoF arm with two grippers for greenhouse tasks. Kinematics by the Denavit–Hartenberg method, dynamics by Lagrangian mechanics, and integration with ROS.
@article{altawil2023design,
  title = {Design and Analysis of a Four DoF Robotic Arm with Two Grippers Used in Agricultural Operations},
  author = {Altawil, Basheer and Can, Fatih Cemal},
  journal = {International Journal of Applied Mathematics Electronics and Computers},
  volume = {11},
  number = {2},
  pages = {79--87},
  year = {2023},
  doi = {10.18100/ijamec.1217072}
}
-
Automating Farming Operations Using Robotic Technologies
M.Sc. thesis, İzmir Kâtip Çelebi University, 2023
A survey of agricultural robots for monitoring, spraying, harvesting and transport, and a ROS ecosystem that ties middleware, hardware and edge IoT devices together for grasping tasks in farming.
@mastersthesis{altawil2023automating,
  title = {Automating Farming Operations Using Robotic Technologies},
  author = {Altawil, Basheer},
  school = {İzmir Kâtip Çelebi University},
  year = {2023}
}
2022
-
Automating Farming Operations Using Robotics Technologies
ICAT conference, pp. 353–359, 2022
@inproceedings{altawil2022automating,
  title = {Automating Farming Operations Using Robotics Technologies},
  author = {Altawil, Basheer and others},
  booktitle = {ICAT conference},
  pages = {353--359},
  year = {2022}
}
2019
-
Development of a Multi Degrees of Freedom Redundant-Parallel Manipulator
ISSC conference, pp. 540–547, 2019
A redundant planar parallel manipulator with six motors and three degrees of freedom whose serial arms can detach and work alone.
@inproceedings{altawil2019development,
  title = {Development of a Multi Degrees of Freedom Redundant-Parallel Manipulator},
  author = {Altawil, Basheer and others},
  booktitle = {ISSC conference},
  pages = {540--547},
  year = {2019}
}